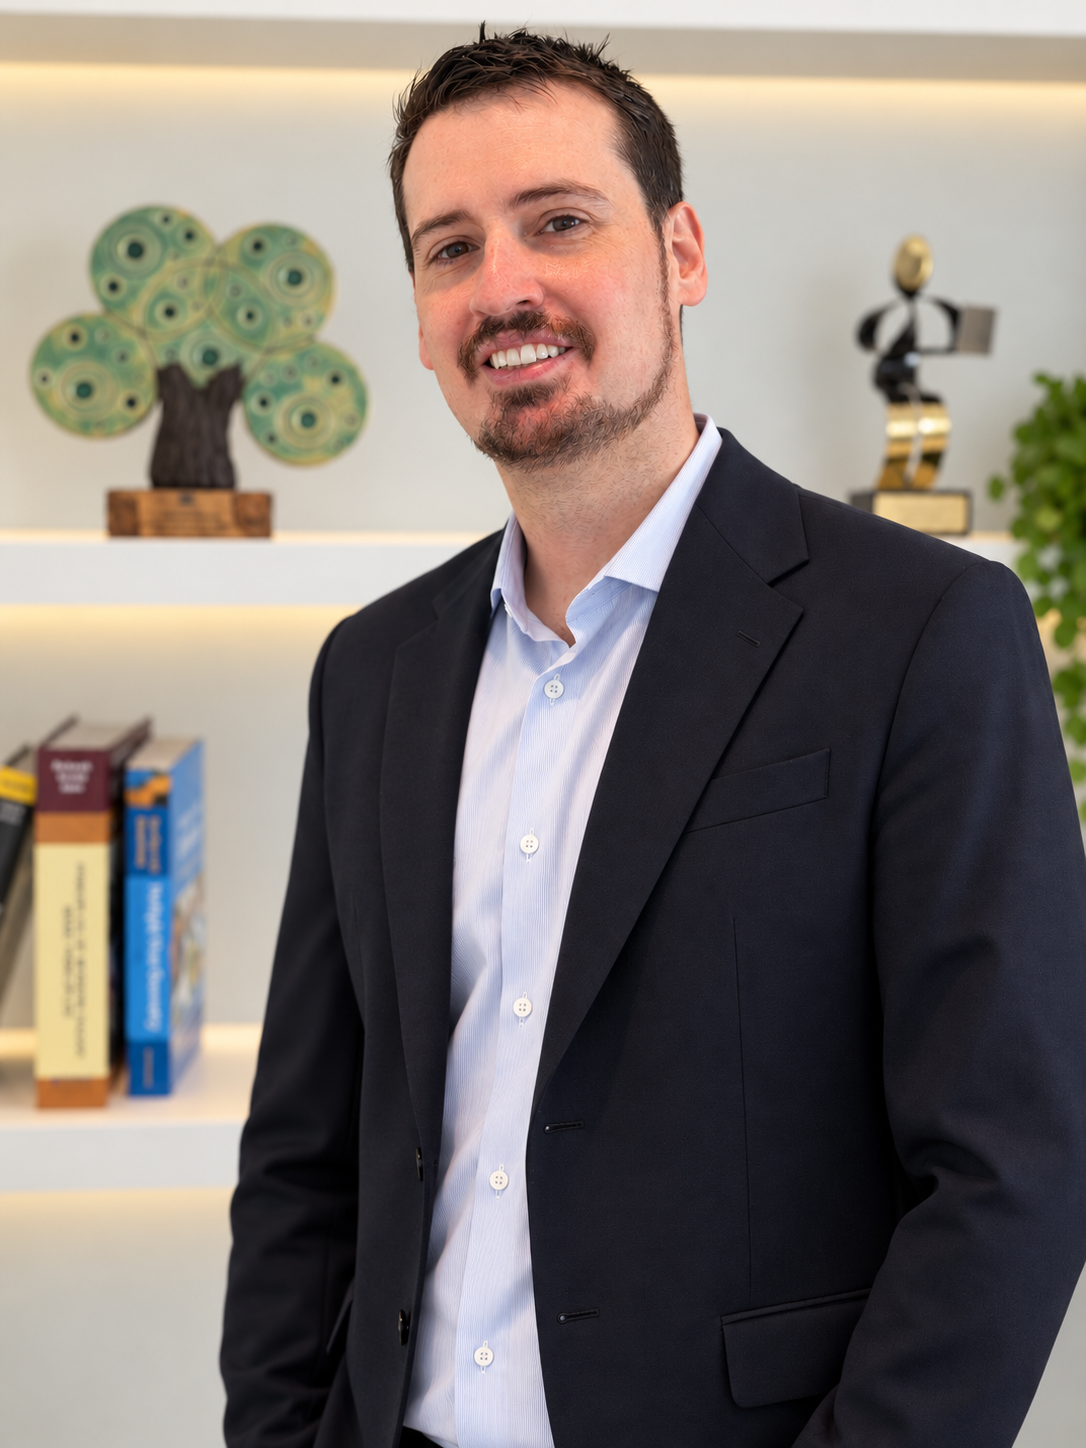
German Ros, Ph.D
Physical AI · Simulation · Synthetic Data
I am a Principal Scientist in Physical AI Research and Director of Simulation Ecosystem Development at NVIDIA.
- Research
- I lead global research and engineering efforts to build the platforms, workflows, and infrastructure that enable intelligent systems to learn and operate in the physical world. My work connects research to products, with a focus on simulation, synthetic data, and the training and validation of capable, safe autonomous systems.
- Open source
- Through foundational work on SYNTHIA and CARLA, I have helped advance the use of synthetic data and simulation for autonomous driving and Physical AI. I lead the CARLA organization and have helped grow open-source communities around CARLA and Open3D. As a strong open-source advocate and co-founder of the Physical AI Foundation, I work to make Physical AI technologies accessible to researchers, developers, and industry.
- Background
- Before joining NVIDIA, I directed the Autonomous Agents Lab at Intel Labs, and served as Principal Investigator for DARPA RACER-SIM, leading an international consortium developing simulation technologies for off-road autonomy. Earlier, I was a Research Scientist at the Toyota Research Institute, working on computer vision, sensor simulation, and sim-to-real for autonomous driving. I earned my PhD in Computer Vision, cum laude, from the Universitat Autònoma de Barcelona and the Computer Vision Center in 2016.
News
Check out the results of the CARLA Autonomous Driving Challenge 2024, part of the Autonomous Grand Challenge at the CVPR 2024 Workshop on Foundation Models for Autonomous Systems.
Our photorealistic UrbanSyn dataset is now available on Hugging Face.
Our new dataset on 3D object relighting is out. Read the paper.
Recent Talks
Synthetic Data Workflows to Accelerate AV: A CARLA Perspective
ELLIS Summer School on Autonomous Driving · Barcelona, Spain
Modern Development of Autonomous Vehicles
Artificial Intelligence and Cybersecurity Summit · Murcia, Spain
The Evolution of Physical AI: End-to-End and the Technologies That Drive the Change
Jaén, Spain
Safety and Open-Source in AV
IAA Mobility Munich (NVIDIA Halos Day) · Munich, Germany
Open-Source Autonomous Vehicle Simulation With CARLA
NVIDIA GTC 2024
CARLA: An Open Simulation Framework and Platform for Autonomous Driving
IEEE Standards Association Symposium on Autonomous Driving
IROS Workshop on Photorealistic Image and Environment Synthesis for Robotics
Academic Service
Chair and organizer of international workshops and challenges.
- 2026
AV Causal Scenario Retrieval Challenge
NeurIPS 2026 · World Models in Physical AI · Sydney, Australia
- 2026
NeurIPS 2026 · Sydney, Australia
- 2020–2026
CVPR · Annual editions, 2020–2026
- 2024
CVPR 2024 · Foundation Models for Autonomous Systems workshop
- 2024
- 2020–2023
Machine Learning for Autonomous Driving (ML4AD)
Co-located with NeurIPS · Annual editions, 2020–2023
- 2019
Computer Graphics for Autonomous Vehicles
ACM SIGGRAPH 2019
- 2019
CARLA Autonomous Driving Challenge
CVPR 2019
- 2016
Virtual/Augmented Reality for Visual Artificial Intelligence (VARVAI)
ECCV 2016 · Amsterdam, Netherlands
Publications
Latest 10 publications · Google Scholar
- 2026
- 2026
- 2025
- 2025
- 2025
- 2025
- 2024
- 2024
- 2022
- 2022
Recent publications are temporarily unavailable.